 LiDAR Applications
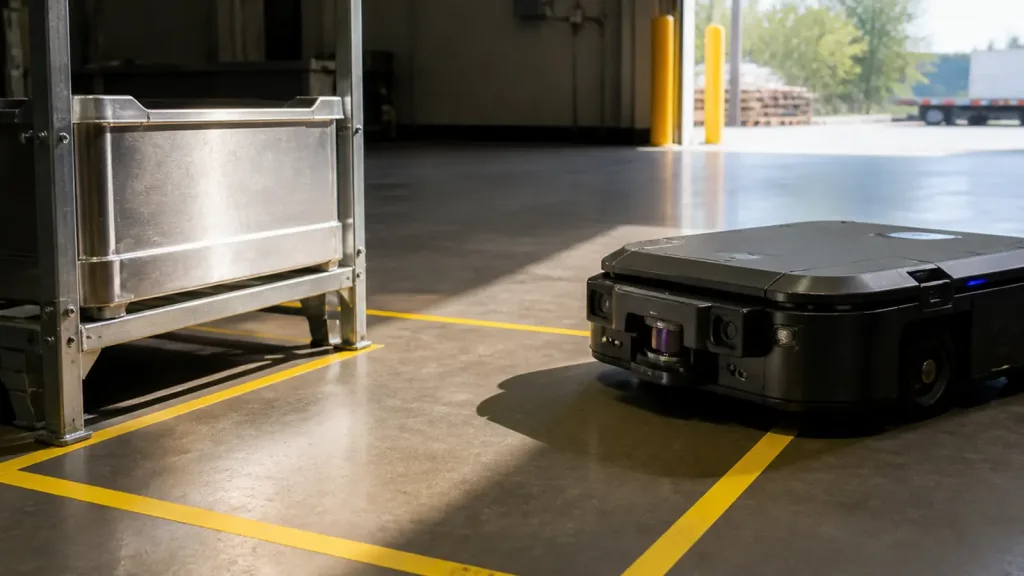
A practical guide for robotics teams that need to approve a compact LiDAR module with pilot-cell evidence for coverage, timing, mixed-light behavior, and failure replay.
 LiDAR Applications
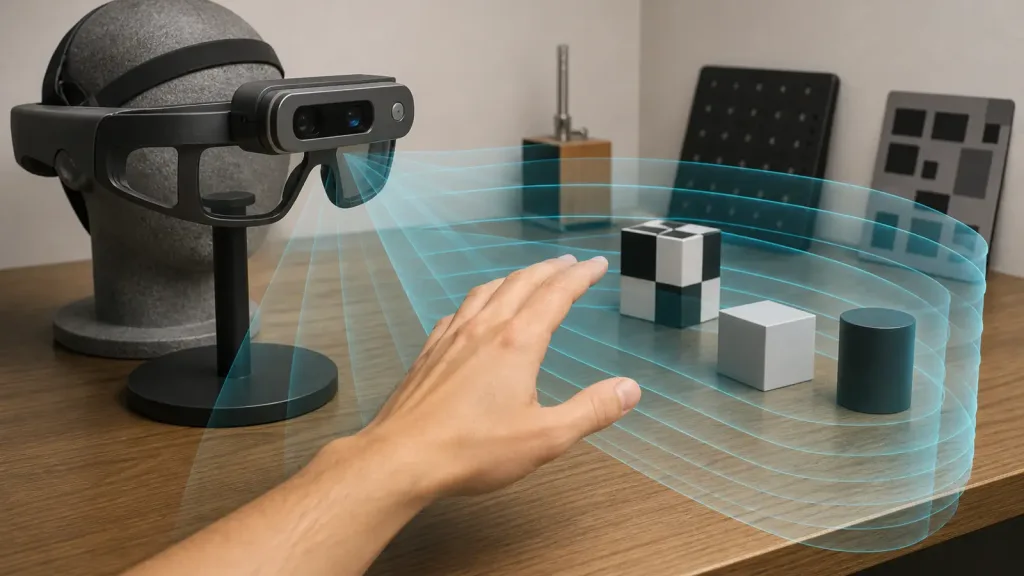
A practical AR VR depth dToF module guide for prototype teams that need to verify near-field scene fit, gesture reach, host output, and mounting before moving a compact depth sensor forward.
 LiDAR Applications
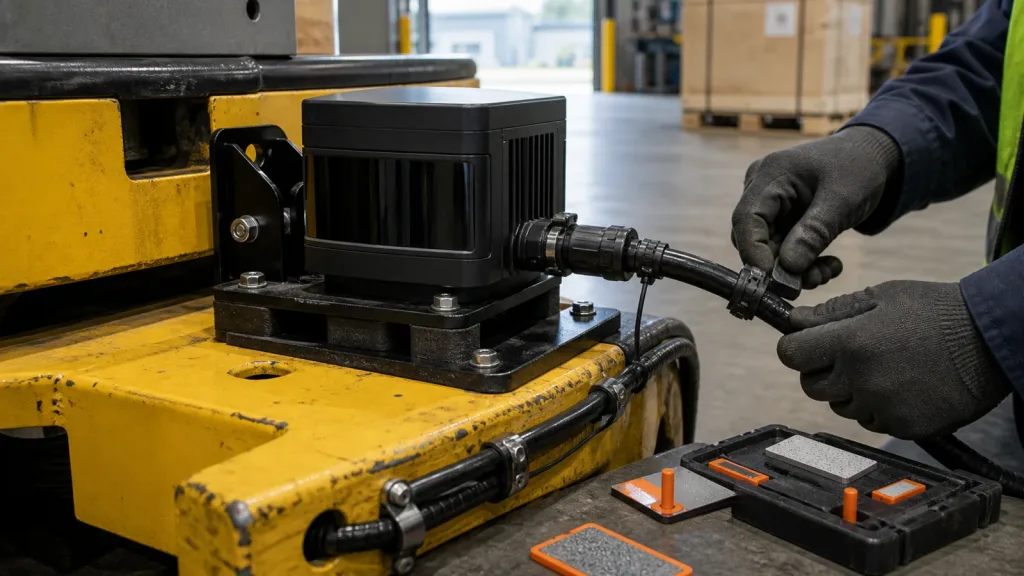
A practical buyer guide explaining what teams must verify before calling a compact solid-state LiDAR module industrial grade for pilot deployment.
 LiDAR Applications
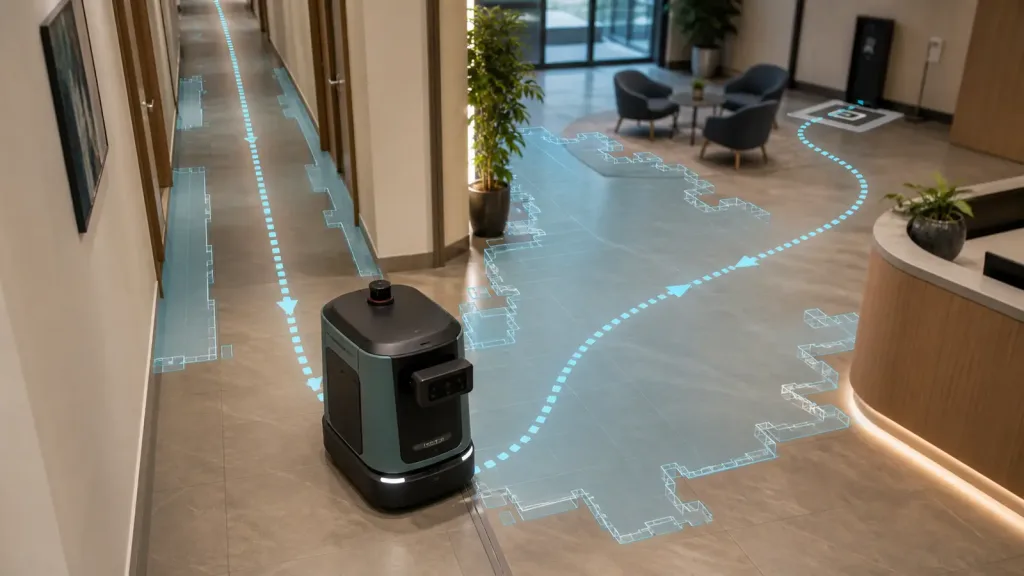
slam navigation dToF lidar for service robot validation starts with repetitive-corridor coverage, stable map ownership, and a dock return that still makes sense when the robot leaves the hallway for a wider lobby.
 LiDAR Applications
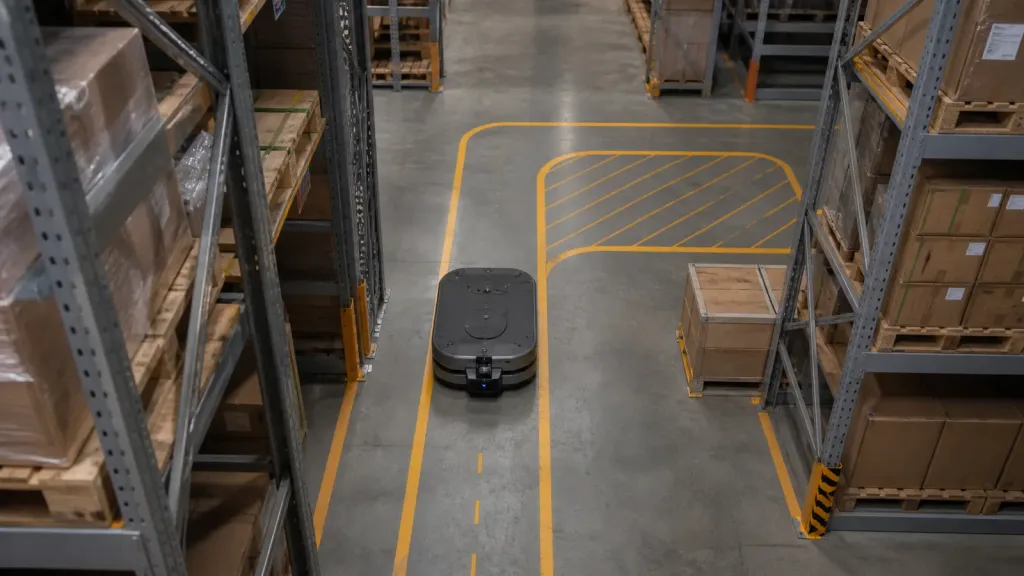
AGV AMR navigation LiDAR validation starts with stable transforms, clear costmap inputs, and route evidence that still holds at shelf legs, pallet corners, and pilot-route turns.
 LiDAR Applications
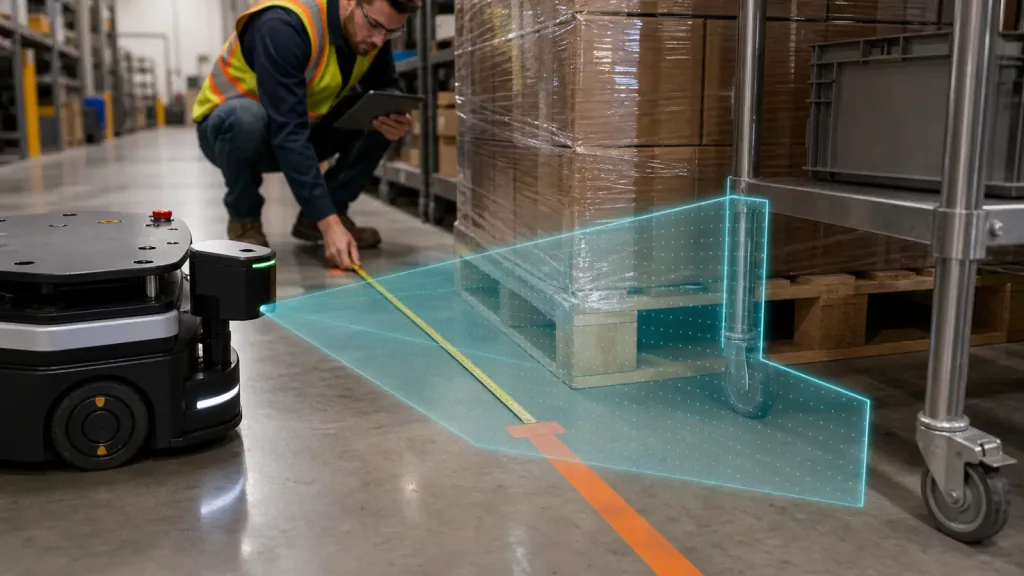
LiDAR for Robotics validation guide for compact solid-state dToF modules: verify coverage geometry, depth resolution, and host handoff before approving a pilot robot build.
 LiDAR Applications
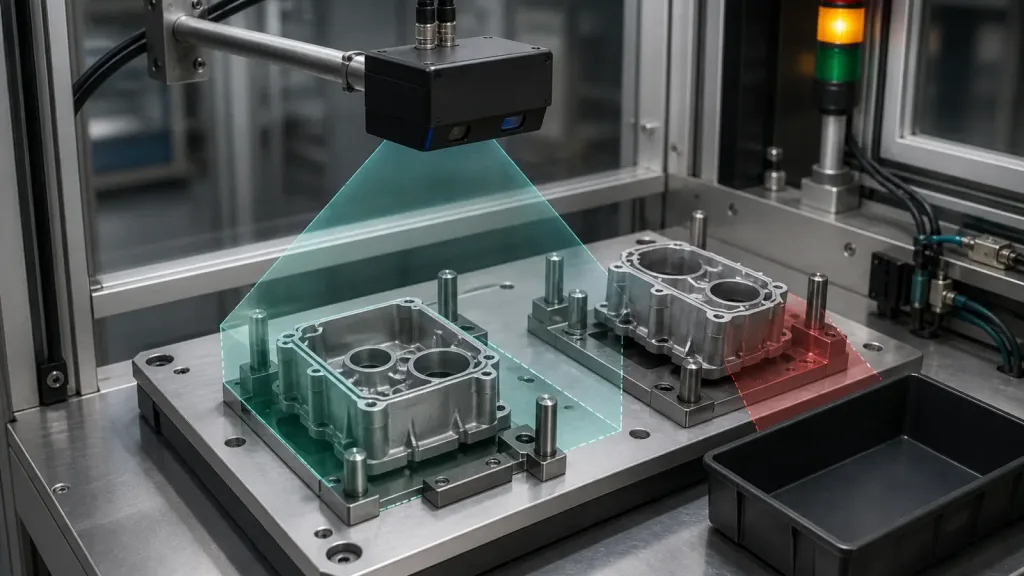
A practical validation workflow for using a compact industrial inspection 3D depth sensor on reflective parts, fixture blind spots, and QA handoff before a pilot line goes live.
 LiDAR Applications
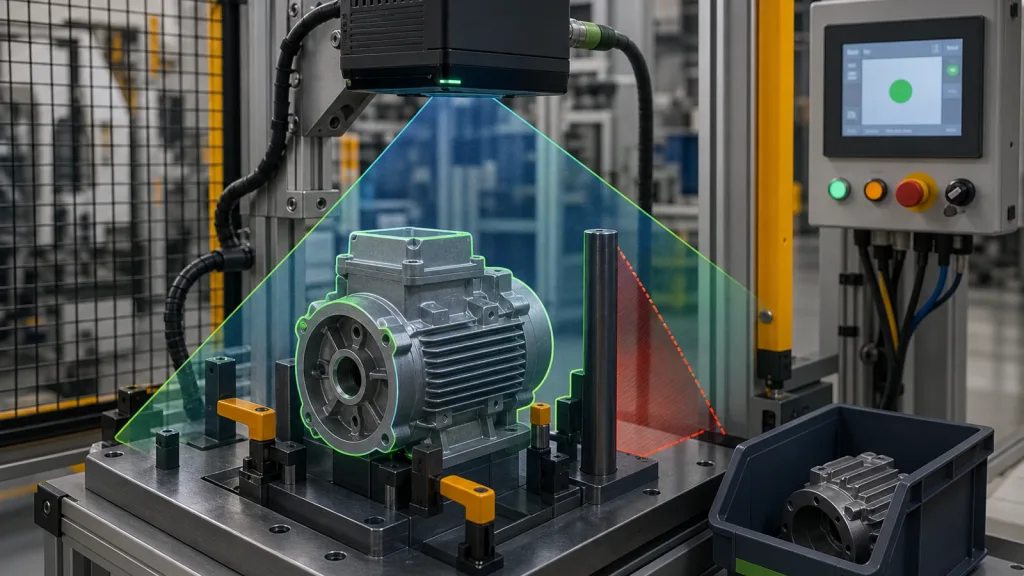
A practical validation workflow for industrial inspection solid state lidar, focused on reflective parts, fixture blind zones, and PLC handoff before pilot approval.
 LiDAR Applications
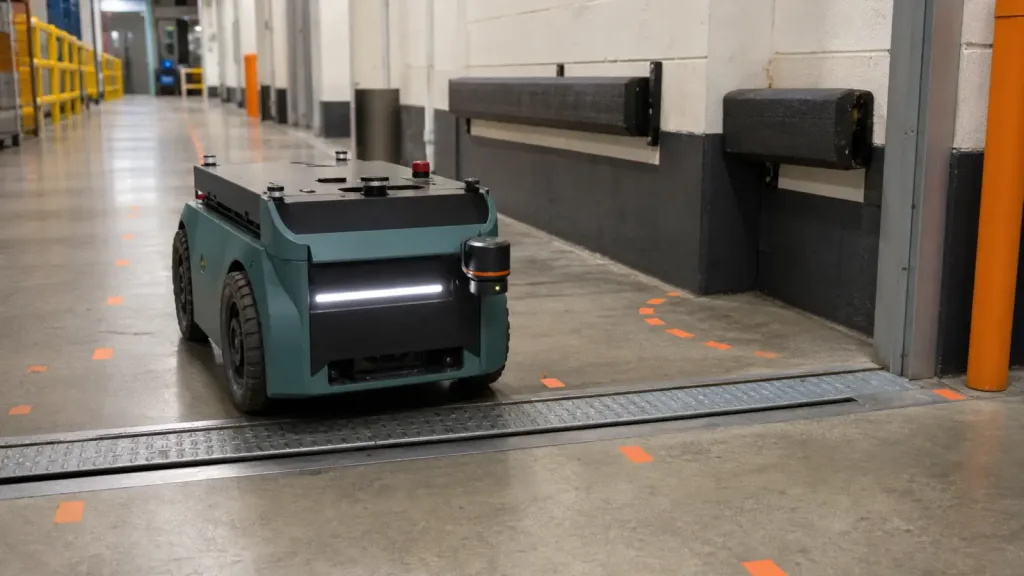
A practical buyer and integration guide to evaluating solid-state laser radar on compact mobile robots, with blind-zone checks, field-of-view mapping, and host-interface planning before sample approval.
