Robotics perception LiDAR usually fails after a tidy demo, not during it. A compact module can look convincing on a bench and still mislead an integration team once the robot enters a pilot cell with reflective totes, doorway shadows, tighter stop distances, and timing pressure from the rest of the stack.
This guide is for robotics integration leads, AMR developers, and technical buyers who need a real acceptance decision rather than a brochure impression. The question is not whether a module can output depth. The question is whether it can keep the required zone observable, time-aligned, and explainable when the robot moves through the mixed-light scene your pilot actually has.
| Quick answer | Approve a robotics perception LiDAR module only after repeated pilot-cell runs prove decision-zone coverage, timing sanity, mixed-light repeatability, and replayable failure evidence. |
|---|---|
| Best fit | Teams qualifying a compact dToF module for an inspection robot, service robot, AMR, or other cell-level perception workflow. |
| Decision rule | If the team cannot show what the robot saw, when it saw it, and how the system behaved after a miss, the module is not ready for pilot sign-off. |
How to qualify robotics perception LiDAR for a real pilot cell
For an integration lead, robotics perception LiDAR should mean more than a point cloud or depth map that looks plausible on a laptop. It should mean the robot can keep the right physical zone readable at the right time, with enough evidence to explain a miss later. NIST's current perception-performance work is useful because it frames perception as a measurement problem, not a slogan. Their work explicitly calls out varying ambient lighting and geometric-feature resolution as issues that deserve metrics and test methods before users trust a system in practice.
That mindset matters for compact modules. A published outdoor range or ambient-light number can tell you what to test, but it cannot tell you whether the robot will correctly read the tote edge, pallet corner, or stop box that actually governs your pilot. The module, the mounting angle, the host timestamps, and the decision logic all have to survive the same scene together.
A current 2026 LiDAR-perception paper reinforces that point. The reported framework was validated across 72 scenarios and improved materially when tracking was integrated, which is a direct reminder that robust perception is proven across varied runs, not a single favorable pass. Another current accepted paper on LiDAR intensity makes the illumination issue clear from a different angle: robotic perception quality changes with lighting behavior, and sparse low-cost LiDAR data still creates limits that a buyer must test in context rather than ignore.
Decision table for pilot-cell acceptance
| Evaluation area | What to verify | Why it matters | Reject if |
|---|---|---|---|
| Decision-zone coverage | Can the module keep the actual stop box, tote edge, or obstacle face visible at the mounted angle? | The robot succeeds or fails at a specific zone, not at an abstract maximum range. | Critical edges disappear at the same posture the pilot requires. |
| Timestamp and frame sanity | Do the logs preserve consistent timing, mounting assumptions, and frame interpretation across repeated runs? | A perception issue and a timing issue can look identical in field tests if the evidence is weak. | The team cannot align what the robot did with what the LiDAR reported. |
| Mixed-light repeatability | Does the module keep usable behavior when the robot crosses a sun-shadow boundary or faces reflective hardware? | Most compact-module surprises happen when the cell lighting changes, not when the robot is parked. | The output becomes unstable or inconsistent when brightness or reflectivity changes slightly. |
| Recovery behavior | After brief occlusion, glare, or clutter, does the perception output recover quickly enough for the downstream decision? | Pilot failures often come from recovery lag rather than total signal loss. | The robot needs a valid update before the module or stack can deliver one again. |
| Replayable evidence | Can the team replay the event path after a failure without rebuilding the entire setup? | Without replay, every miss becomes opinion instead of diagnosis. | The module cannot be approved or debugged from the captured data. |
Exact featured-product facts to validate first
The current Featured WooCommerce product for this workflow is the LiDAR Drone Module - MRP-LD1 Solid-State dToF Sensor. For a robotics perception acceptance run, these are the exact facts that can be used without invention.
| Parameter | Published value | Acceptance implication |
|---|---|---|
| Ranging principle | dTOF | Use timing-based depth evidence, not a generic proximity-only check. |
| Scanning principle | SPAD | Stress mixed lighting and edge stability rather than treating any return as good enough. |
| Wavelength | 940nm VCSEL | Include the real window materials and reflective surfaces from the pilot scene. |
| Ambient-light resistance | 80Klux | Turn the number into a measured scene test instead of a trust statement. |
| Range | Indoor 0.5-25m / outdoor 0.2-8m | Translate this into the actual stand-off distance of the robot's decision zone. |
| Accuracy | 0.2-1m <= +/-3cm; 1-5m <= +/-5cm; 5-8m <= +/-10cm; 8-15m <= +/-20cm | Set pass-fail tolerances around the cell geometry that really matters. |
| Field of view | 60 degrees x 45 degrees | Map whether the stop box, tote edge, or obstacle face stays inside the usable cone. |
| Output | 40 x 30 at 10fps | Confirm the spatial granularity and update rate still fit the robot's reaction path. |
| Interfaces | UART / UVC / UDP | Choose the path that makes logging and replay easiest before you optimize the embed. |
| Software support | Windows / ARM / Linux / Android | Prototype quickly, but still verify the final host path you plan to ship. |
| Power / weight | 5V, 1.2W, 8g | Convenient for compact robots, but not evidence that the perception task is solved. |
A practical acceptance workflow
1. Define the exact robot decision you need to protect
Start with one decision, not a vague ambition. For example: stop before the tote edge enters the gripper path, hold clear of the pallet corner during approach, or detect the keep-out box boundary before the robot crosses it. If your team still needs the broader pilot checklist around mounting, tolerances, and evaluation discipline, use Purpleriver's LiDAR sensor validation guide first, then narrow the work to the single decision zone that makes or breaks this pilot.
2. Map the surfaces and light transitions inside that zone
Write down the materials and lighting that can distort confidence: reflective metal tote walls, glossy shrink wrap, painted floor boxes, bright daylight from a door, or deep shade from a rack. The goal is not to recreate a laboratory paper. The goal is to make sure the exact scene that matters can be repeated and judged again.
3. Lock the mount, timing assumptions, and review path
Before the first run, freeze the sensor height, tilt, and host path you intend to evaluate. If those change between passes, your acceptance result becomes ambiguous. This is also where route-scale articles such as Purpleriver's robotics mapping LiDAR guide stop being enough. Route planning can tolerate broader assumptions; cell acceptance cannot.
4. Run repeated passes through the same trigger points
Drive the robot through the approach, pause, and retreat sequence multiple times with the same starting pose. Then vary only one factor at a time: a slightly different angle, a brighter doorway, a shinier tote, or a small offset in the stop point. This reveals whether the module is robust or merely lucky.
5. Test what happens after a short perception disruption
The most expensive failures are often brief. A tote edge disappears for a moment, the sun-shadow boundary crosses the field, or the robot body motion causes a short inconsistency. The important question is how quickly the stack recovers, and whether the downstream behavior remains safe and understandable while that recovery happens.
6. Approve the module only if the evidence pack is useful to the next engineer
A good acceptance package should let another engineer replay the failure, understand the scene, and decide whether the issue belongs to the sensor, the mounting, the host parsing, or the robot logic. If the result cannot survive that handoff, the pilot is not ready.
Interface, data, and proof capture
Perception approvals fail when the evidence path is weaker than the sensor test. Keep the capture plan explicit.
| Integration topic | What to capture | Pass condition |
|---|---|---|
| Logging path | Raw or processed depth output, timestamps, robot state, and scene notes for each pass | A failure can be replayed without rerunning the cell immediately. |
| Interface choice | One consistent early-stage path for UART, UVC, or UDP during acceptance | The team can compare runs without wondering whether the transport changed the result. |
| Scene context | Photos of the light boundary, target surfaces, and mount angle used in the pass | Anyone reviewing the result can reconstruct the meaningful geometry. |
| Recovery event review | The short window before, during, and after an occlusion or unstable return | The team can separate a perception defect from a host-side interpretation defect. |
For the MRP-LD1, Purpleriver's UART, UVC, or UDP guide, the documentation hub, and the sample datasets page are the best internal resources to line up before you shrink the evidence path for deployment.
If the team already struggles with unexplained mismatches between what the robot did and what the logs show, revisit Purpleriver's guide to common LiDAR integration issues before you declare the sensor guilty.
Realistic application case: mixed-light pallet handoff cell
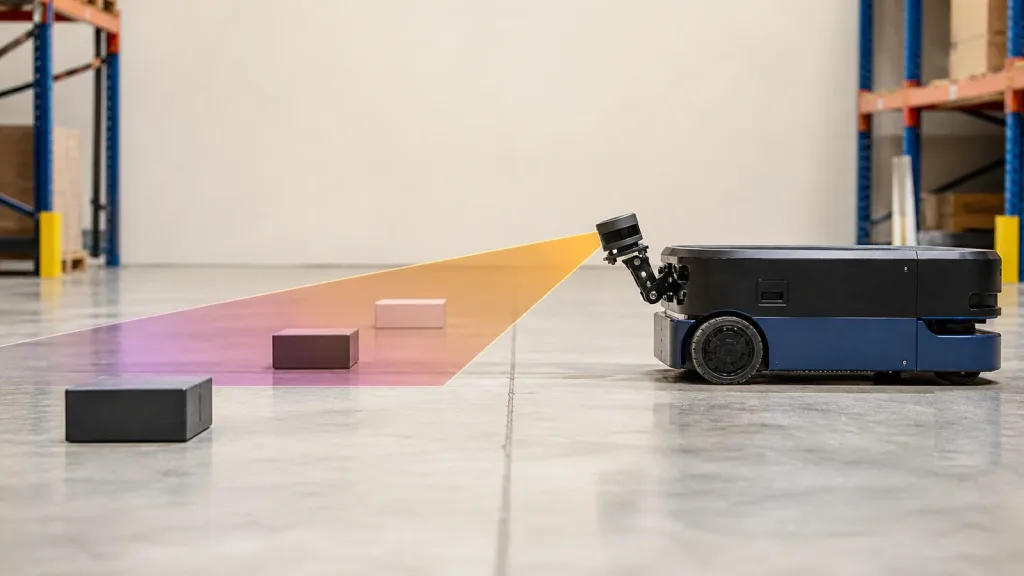
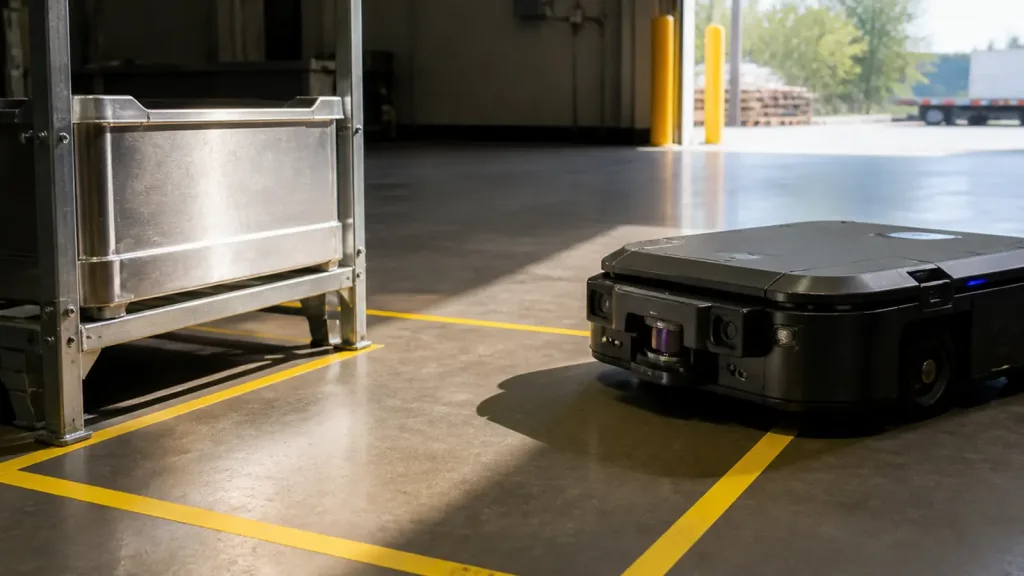
Consider a compact inspection robot approaching a pallet handoff box in a production cell. A reflective metal tote rack stands on the left, yellow floor tape marks the handoff area, and daylight spills from an open roll-up door in the back right. The robot must slow, recognize the tote edge and box boundary, and stop before its tool path enters the protected space.
This is not the same problem as route-scale AMR navigation. The robot is not proving that it can traverse a warehouse. It is proving that one local decision zone stays readable when contrast, reflectivity, and motion all interact inside a narrow cell.
- Mount the module at the same height and tilt the robot will actually use.
- Record the scene with the door open and closed, then again with the tote shifted slightly.
- Repeat the same approach path until the stop event and retreat path are consistent enough to compare.
- Mark the passes where the light boundary crosses the target zone and review those logs first.
- Reject the setup if the tote edge or floor boundary becomes ambiguous when the scene changes only a little.
This case stays inside the MRP-LD1's documented application scope for robot navigation, obstacle avoidance, and industrial inspection without inventing any unsupported product promise.
Common mistakes
- Using a hallway or bench pass as a proxy for a mixed-light pilot cell.
- Testing only a range number instead of the actual decision zone the robot must protect.
- Changing the mount or host path between runs and then trusting the comparison anyway.
- Ignoring brief recovery failures because the module eventually returns to normal.
- Optimizing the embedded interface too early and losing clean replay evidence.
- Assuming a published ambient-light or outdoor range value already proves cell readiness.
RFQ and pilot-approval checklist
| Checklist item | Why it belongs in the approval review |
|---|---|
| Decision-zone definition | Prevents the team from approving a sensor that solves the wrong problem well. |
| Measured scene description | Lets reviewers connect a pass or fail to real materials and lighting. |
| Mount and host freeze point | Stops the acceptance run from drifting into an apples-to-oranges comparison. |
| Repeated pass evidence | Shows whether the result is robust or just favorable once. |
| Recovery review window | Catches short disruptions that can still break the robot behavior. |
| Replayable logs | Makes the result useful after the pilot leaves the cell. |
| Ownership of follow-up actions | Clarifies whether the next fix belongs to optics, firmware, parsing, or robot logic. |
When the module is ready for a real go or no-go call
If the evidence pack shows stable zone visibility, understandable timing, mixed-light repeatability, and usable replay after disruptions, the module is finally approaching a credible pilot decision. If it does not, buying pressure should not outrun debugging discipline.
Purpleriver's featured MRP-LD1 solid-state dToF sensor is relevant for teams evaluating compact perception hardware in robot navigation, obstacle avoidance, and inspection workflows. To discuss fit for your own pilot cell, use the contact page and include the zone geometry, robot speed, target materials, and lighting transition you need to validate.