 Integration & SDK
An evidence-first dToF LiDAR FAQ for integration teams: document the module facts, bound the scene, retain the host handoff and decide what still needs validation.
 Drone Obstacle Avoidance
A practical downward sensing validation guide for UAV teams: prove the installed view, representative ground evidence, host data contract, and tested handoff before treating a compact depth module as a low-altitude input.
 Integration & SDK
Use an evidence map to evaluate listed power, Class 1 documentation, data output, and host integration for a compact solid-state LiDAR module.
 Data & Point Cloud
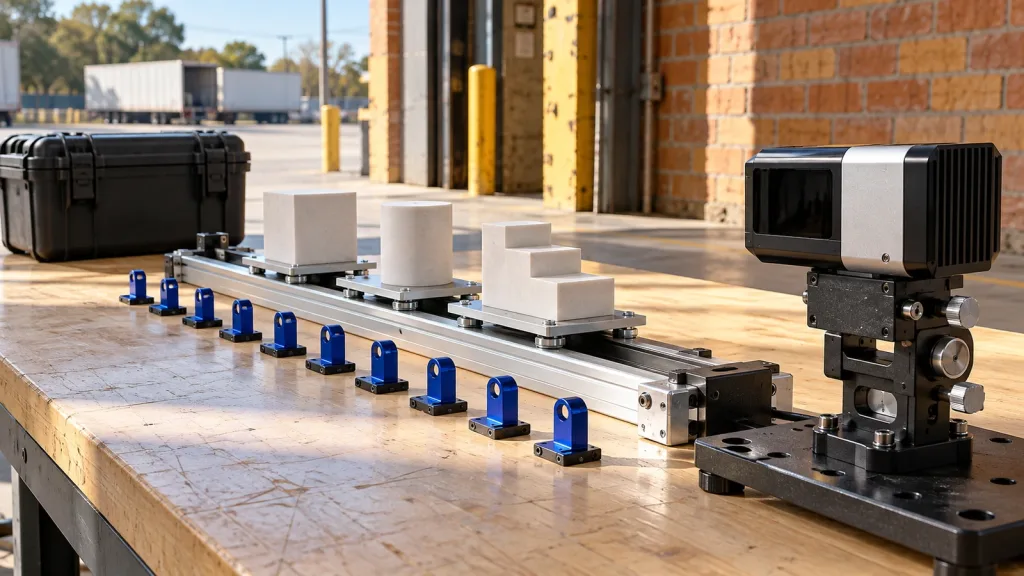
A practical capture-to-archive acceptance plan for evaluating a 10fps 3D point cloud LiDAR sensor before mapping, perception, or control claims.
 Drone Obstacle Avoidance
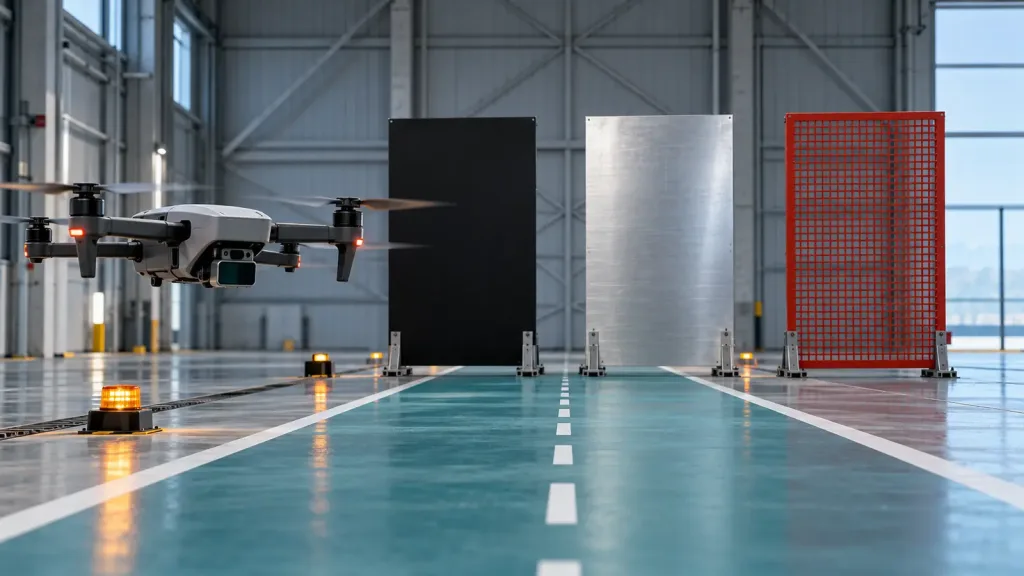
A practical evidence guide for evaluating a UAV obstacle avoidance sensor: map coverage, data handoff, delay, response, and no-data behavior before flight.
 Integration & SDK
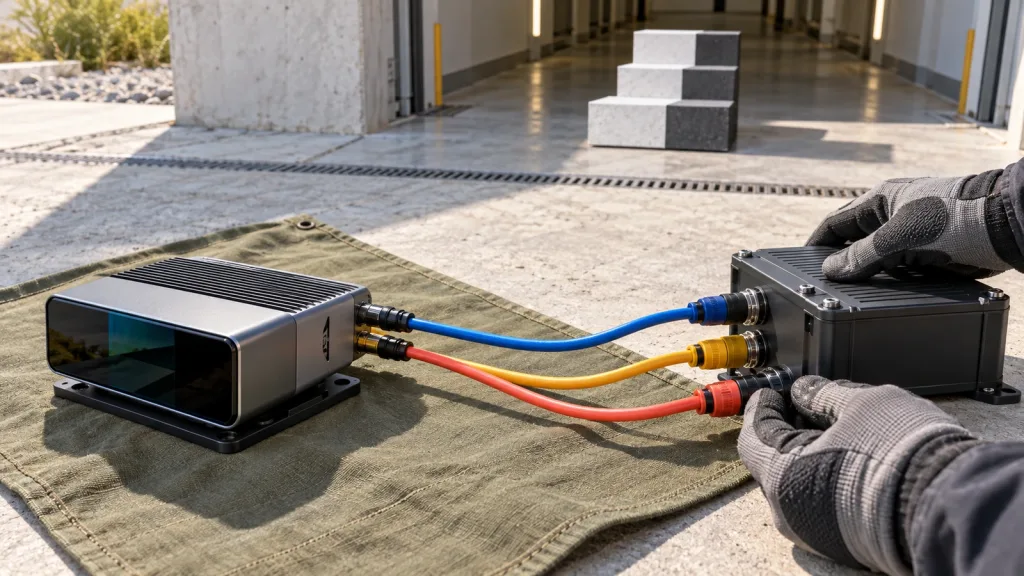
A buyer’s evidence checklist for separating documented compact-LiDAR facts from the project-owned SDK, ROS message, transform, replay, and failure-state work needed for a testable integration path.