 Drone Obstacle Avoidance
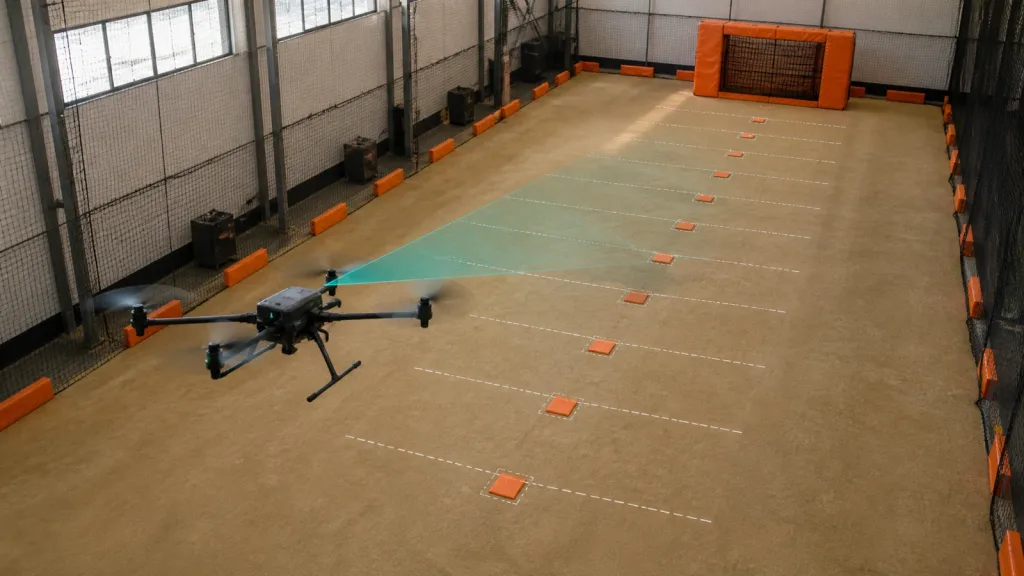
Calculate and validate drone obstacle avoidance distance from speed, measured pipeline delay, deceleration, separation margin, uncertainty, and usable sensor range.
 Drone Obstacle Avoidance
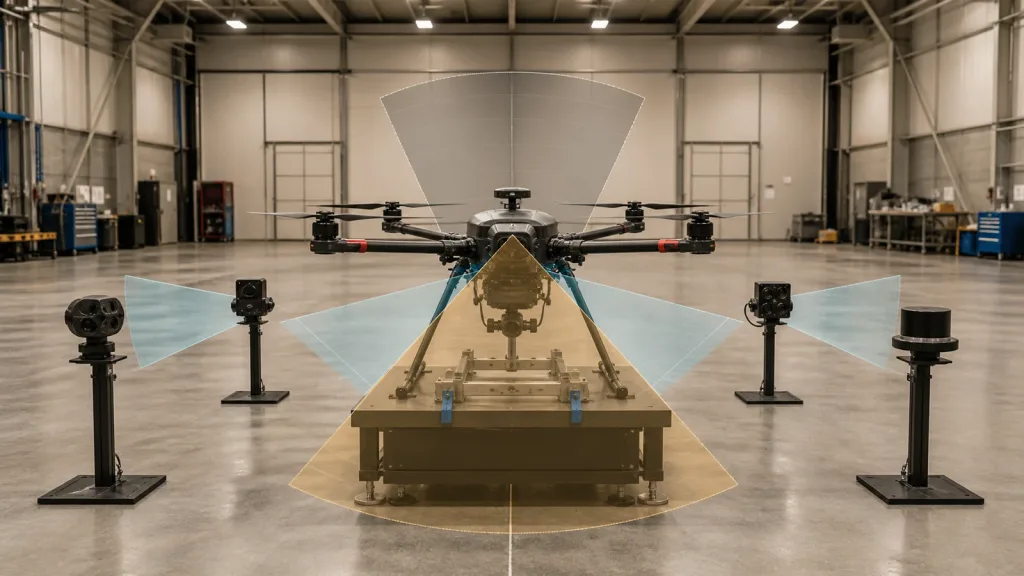
Choose a drone collision avoidance sensor by coverage, usable range, update timing, target conditions, host integration, and failure behavior—not headline range alone.
Drone Obstacle Avoidance
Learn how sensing, localization, planning, decision logic and flight control work together so drones can navigate and respond to obstacles.
Drone Obstacle Avoidance
Compare LiDAR, cameras, ultrasonic sensing and radar for drone collision avoidance, then build a system-level sensor selection and validation plan.
 Drone Obstacle Avoidance
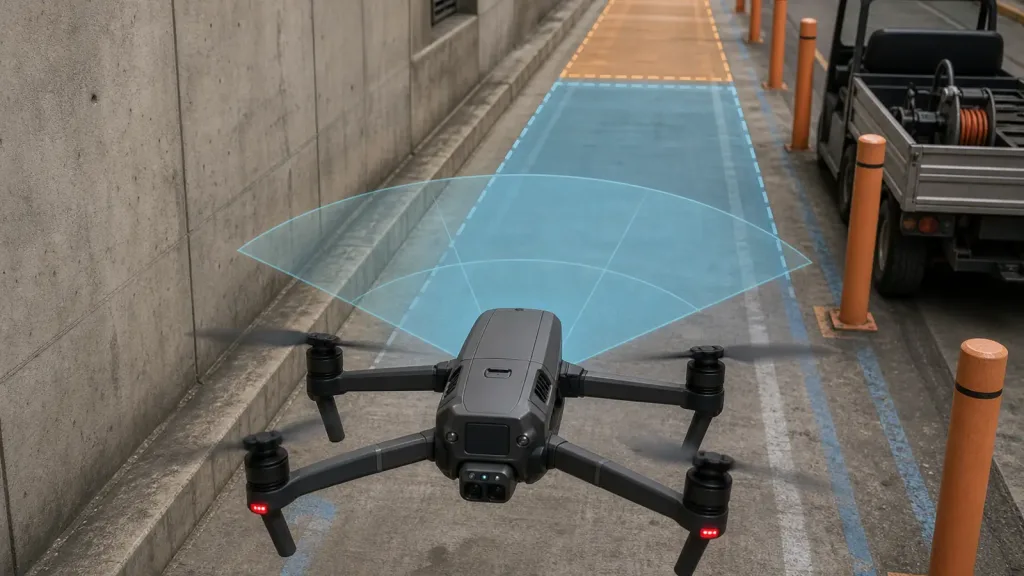
Backward Obstacle Sensing guide for UAV teams validating rear-sector coverage, retreat-speed margin, brake behavior, and replayable evidence before making a rear safety claim.
 Drone Obstacle Avoidance
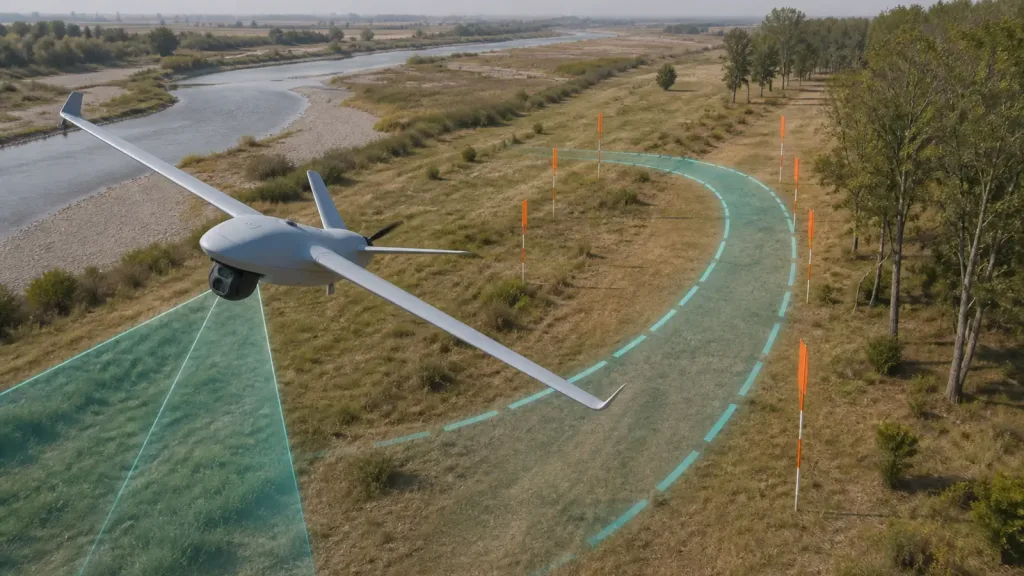
Drone fixed wing obstacle avoidance lidar guide for UAV integrators comparing sensor detection, controller authority, turning geometry, and real avoidance proof.
 Drone Obstacle Avoidance
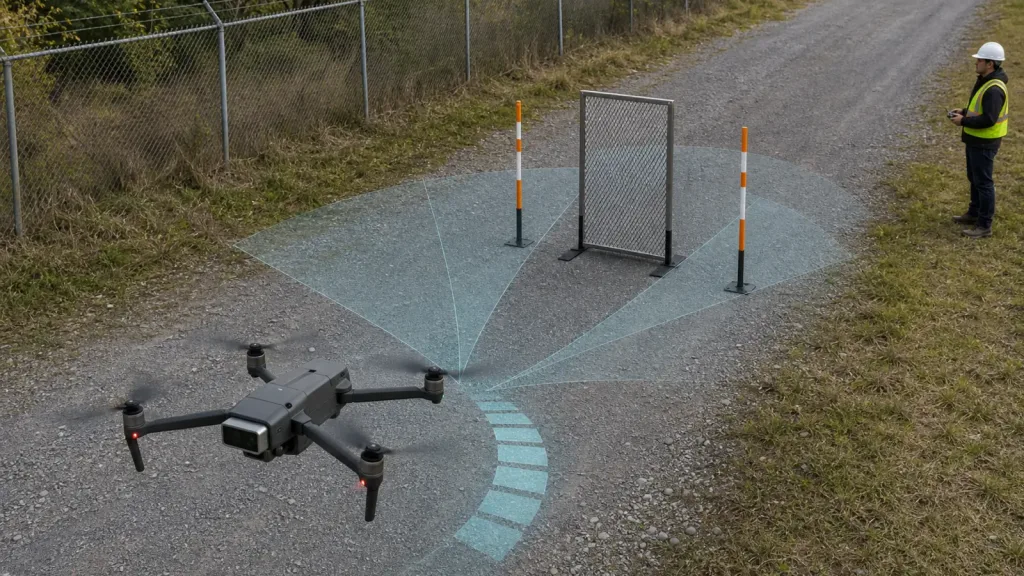
A practical UAV validation guide for proving sector coverage, brake margin, and controller handoff before a compact LiDAR setup is trusted for obstacle avoidance routes.
 Drone Obstacle Avoidance
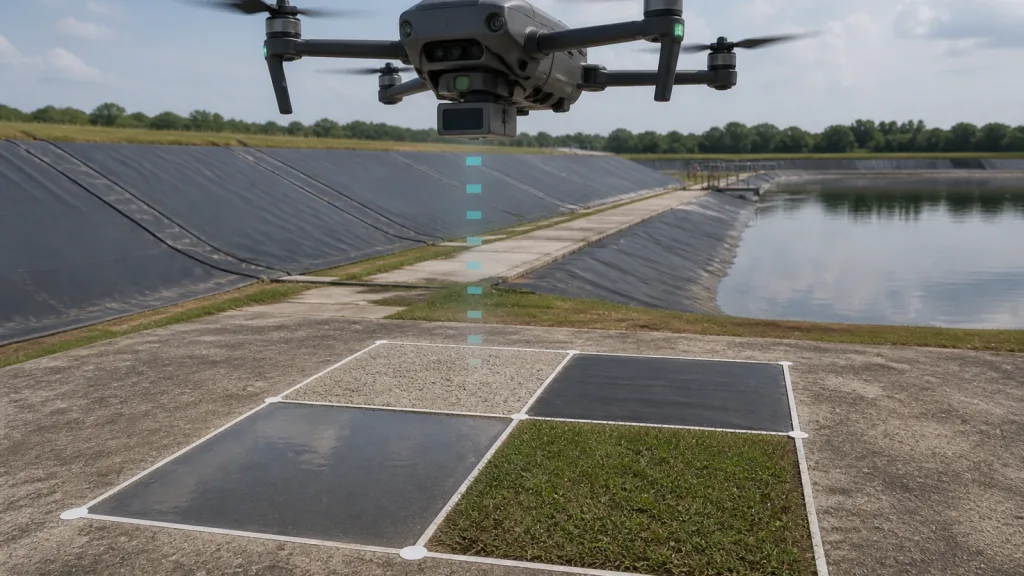
A practical UAV guide explaining how to validate a downward vision system across dark, reflective, and mixed surfaces, and when LiDAR support reduces low-altitude positioning risk.
 Drone Obstacle Avoidance
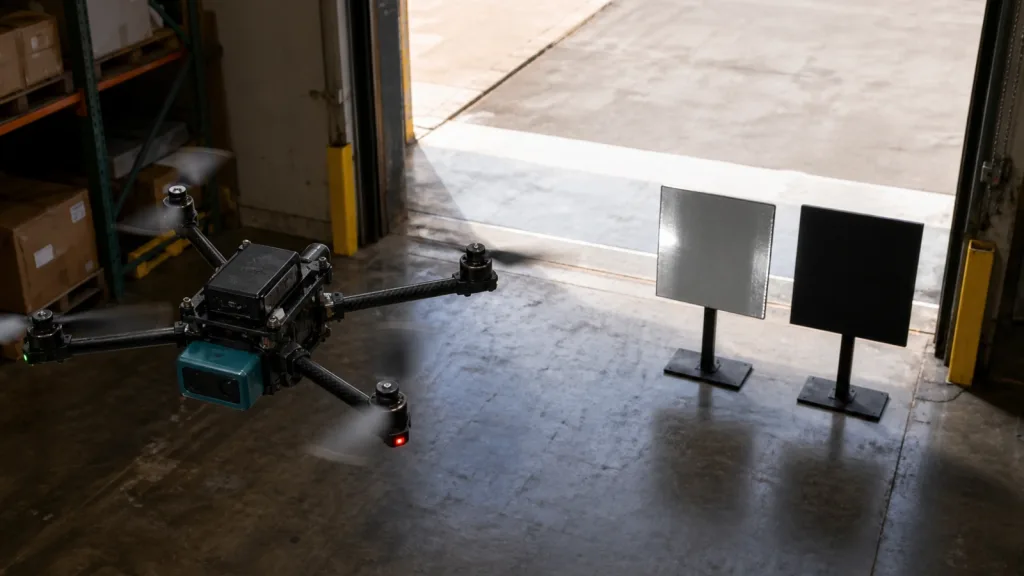
A practical forward obstacle sensing workflow for UAV teams: sector coverage, stop-distance validation, reflective-target checks, and autopilot handoff before close-approach flights.
