For technical buyers: a low quotation is only a starting point. The useful question is whether a compact sensor can produce documented evidence in your actual geometry, target set, and host-data path.
Searching for cheap industrial dToF lidar wholesale usually means a team is trying to reduce the cost and time of a first sensing prototype. That is reasonable—but do not let a unit quote become an acceptance decision. Before requesting a sample, define what must be mounted, what must be observed, what data must arrive at the host, and which conditions make the result meaningful.
Quick answer
Compare an industrial dToF quotation in four gates: module fit, scene fit, data fit, and evidence fit. Ask for the exact configuration and a test plan before interpreting any distance figure. A result is useful only when its target, geometry, conditions, data path, and decision rule are clear. For an initial module shortlist, start with the site’s evaluation-sample checklist.
Cheap Industrial dToF LiDAR Wholesale: What a Quote Can—and Cannot—Tell You
A quote can help a buyer create a shortlist. It cannot by itself show whether the sensor can see the relevant object, provide usable data through the intended host, or satisfy the application’s decision criteria. That distinction matters when the word “cheap” is in the search: economical sourcing should lower the cost of learning, not lower the evidence threshold.
Measurement guidance from NIST Technical Note 1297 is a useful discipline here: a measurement result is more interpretable when it is accompanied by an explicit statement of conditions and uncertainty context. This is not a claim that a supplier’s result is NIST-calibrated. It is a reason to request the conditions, method, and limitations that make a sample result reviewable.
| Buyer question | Evidence to request | Decision it supports |
|---|---|---|
| Will the module physically fit? | Mass, supply requirement, mounting envelope, and the exact module revision being quoted | Whether a first sample can be installed without redesigning the fixture |
| Can it see the relevant scene? | Target material, target size, distance, angle, ambient condition, and mounting geometry | Whether a controlled trial represents the intended use |
| Can the host consume the output? | Chosen interface, message/frame example, data type, host platform, and capture method | Whether engineering can reproduce the bench result on its own host |
| Is the result decision-ready? | Test record, configuration ID, pass/fail rule, and exceptions observed | Whether to refine the trial, request another sample, or proceed |
The four evaluation gates for an industrial dToF quotation
Gate 1: lock the module configuration
Put the exact sensor, interface, host operating system, power arrangement, and intended mounting location in the request. Do not treat a family name as a configuration. The sensing architecture and host-integration boundary need to be named before quotations can be compared; broad product-family context never establishes the output format or integration behavior of the specific module in front of you. Request those facts for the module you are evaluating.
Gate 2: turn the application into a target matrix
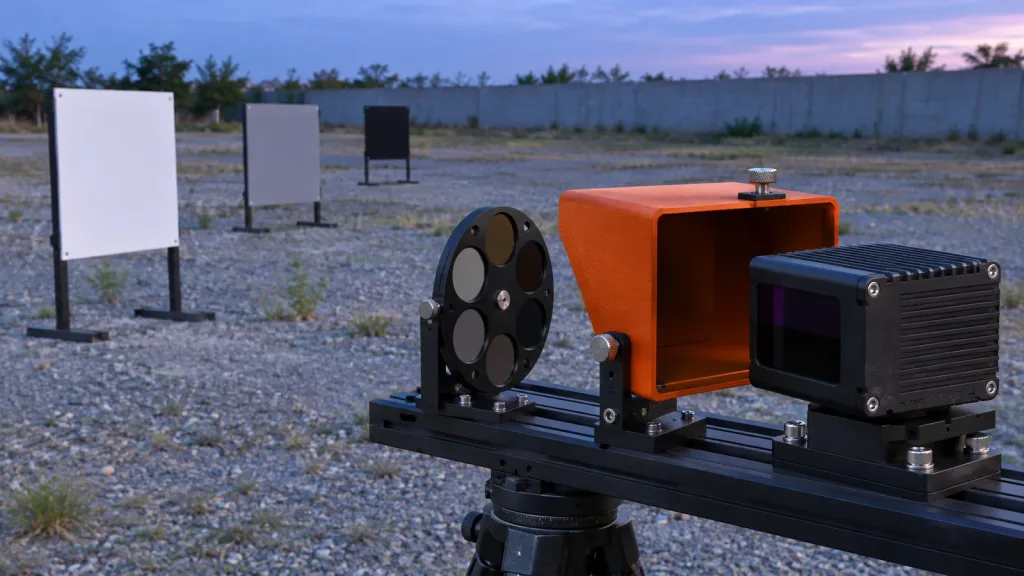
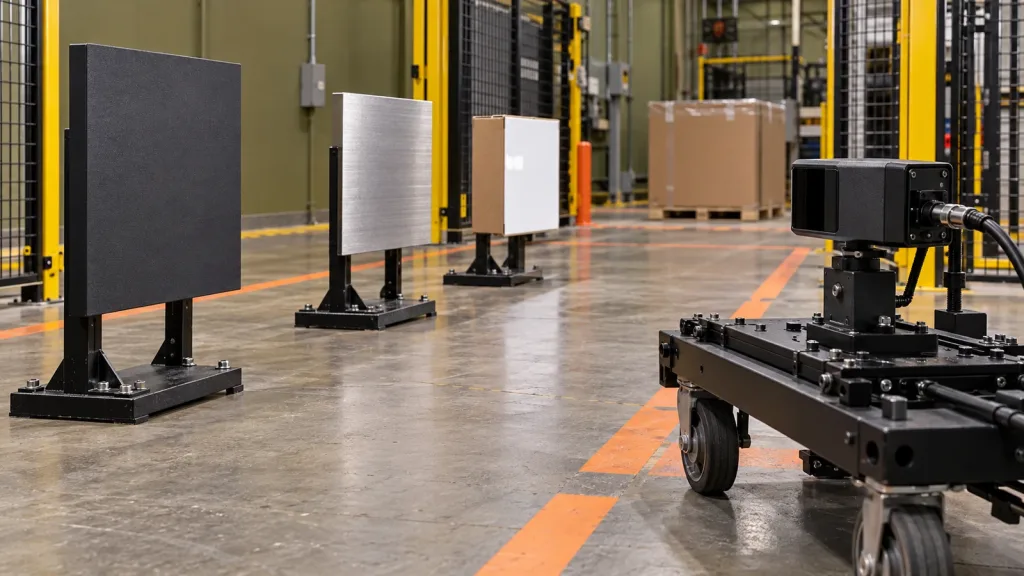
Write down the objects that matter: their material, size, distance, approach angle, and motion. Include difficult-but-real surfaces rather than a single convenient target. If the intended application is an industrial cell, a reasonable first matrix might include a matte target, a brushed-metal target, and a glossy-labeled package corner. That is a test design example, not a claimed MRP-LD1 performance result.
Gate 3: prove the data path before interpreting the picture
Ask how the team will capture, store, decode, and review the data. A correct-looking visualization on a demo setup does not prove that the target host receives the same data with the expected framing and validity handling. Review the site’s UART, UVC, or UDP interface guide and its integration-diagnosis guide before committing the interface choice.
Gate 4: record evidence, not just an outcome
For each run, keep the configuration, target description, placement, lighting condition, captured data, and review rule together. NIST explains that traceability relates a measurement result to a reference through a documented calibration chain, and also cautions that traceability alone does not guarantee fitness for purpose. Use that distinction correctly: documentation helps a buyer assess a result; application-specific testing decides whether the result is sufficient.
MRP-LD1 facts to put in the evaluation request
The following are supplier-provided facts from the current Featured-product export for the MRP-LD1 Drone LiDAR Sensor. They are useful inputs to an evaluation request, not a guarantee of installed performance.
| Listed item | Featured-product value | How to use it in a sample plan |
|---|---|---|
| Sensing architecture | Solid-state SPAD dToF; 940 nm VCSEL | Confirm that the proposed trial and host design match the intended module architecture. |
| Mass and power | 8 g; 1.2 W; 5 V supply | Reserve mounting and power budget, then verify the installed arrangement. |
| Field of view and output | 60° × 45°; 40 × 30; 10 fps; depth image and 3D point cloud | Sketch the field of view against actual target locations before running the trial. |
| Interfaces and software support | UART, UVC, UDP; Windows, ARM, Linux, Android | Name the proposed interface and host in the request; do not assume an unlisted middleware driver. |
| Listed range baseline | 0.5–25 m indoors; 0.2–8 m outdoors | Use only as a screening baseline; test the actual target, angle, ambient light, mounting, and motion. |
| Listed ambient-light resistance | 80 Klux | Record the ambient condition used in the trial rather than treating a listed limit as a universal field result. |
Sample-review case: a packaging-cell target lane
Scenario: a sourcing engineer is evaluating a compact module for an indoor packaging cell. The team does not need a general promise that the module works “in a factory.” It needs evidence for the exact target classes that influence the next engineering decision.
- Mount the module in a repeatable bracket at the intended height and pitch.
- Place three representative targets at planned distances: a matte panel, a brushed-metal panel, and a glossy-labeled package corner.
- Record the target placement, module configuration, ambient condition, selected interface, and raw capture location for each run.
- Review whether the host can distinguish usable readings, unavailable readings, and artifacts under the team’s documented rule.
- Decide whether to adjust geometry, target coverage, data handling, or sample scope. Do not promote a single favorable capture into a deployment claim.
This pattern aligns with the site’s quality-inspection notes for solid-state LiDAR modules: keep the inspection question specific enough that another engineer can repeat the setup.
Data and interface handoff: agree on the contract
Before requesting a wholesale sample, identify who owns each handoff: supplier, electrical engineer, embedded developer, and system test owner. The chosen interface is only the transport layer. The evaluation record should also identify the output type, byte order or image format where applicable, update behavior, validity convention, timestamping approach, and the failure behavior expected by the host. If a detail is undocumented, make it an explicit question—not an assumption.
For the MRP-LD1, the export lists UART, UVC, and UDP plus depth-image and point-cloud output. It does not establish a specific autopilot protocol, middleware package, or end-to-end safety behavior. Keep that boundary in the RFQ and use the article on sensor data contracts and flight-controller integration only when your project truly includes that downstream handoff.
Common mistakes that make a low quote expensive
- Comparing only a headline range. A listed baseline is not your target matrix, mounting geometry, or data-acceptance rule.
- Skipping configuration control. If the interface, firmware context, bracket, or host changes, record the change before comparing captures.
- Using one friendly target. Include the materials and edges that drive the application decision.
- Calling a visualization an integration. Retain a raw capture and reproduce decoding on the intended host.
- Confusing traceability with fitness. Documentation makes a claim assessable; it does not replace the application trial.
- Turning a sensor module into a system claim. A depth source remains only one component of the perception, logic, and response chain.
RFQ and evaluation checklist
| Include in the request | Why it matters |
|---|---|
| Target platform, application, and intended mounting envelope | Sets the physical and geometrical scope of the sample review. |
| Working-distance band, target materials, angles, and indoor/outdoor condition | Creates a test matrix instead of a vague “works or fails” question. |
| Preferred UART, UVC, or UDP path and host operating system | Lets the team plan capture and decoding before hardware arrives. |
| Required output: depth image, point cloud, or both | Prevents a data-type mismatch at the handoff. |
| Configuration identifier and captured-data retention plan | Makes runs comparable and reviewable. |
| Acceptance rule and named engineering owner | Turns a sample into a decision rather than an open-ended demo. |
If your sourcing review must account for broader cost drivers, use the site’s sensor price-factors guide as context—but request a project-specific evaluation path rather than treating an online figure as a final purchasing answer.
Request a documented MRP-LD1 evaluation discussion
Share your target platform, working-distance band, target materials, environment, host system, preferred interface, sample quantity, and expected project timing. Purpleriver can then help route your request to the appropriate product documentation, SDK resources, sample data, evaluation sample, or project-specific quote.