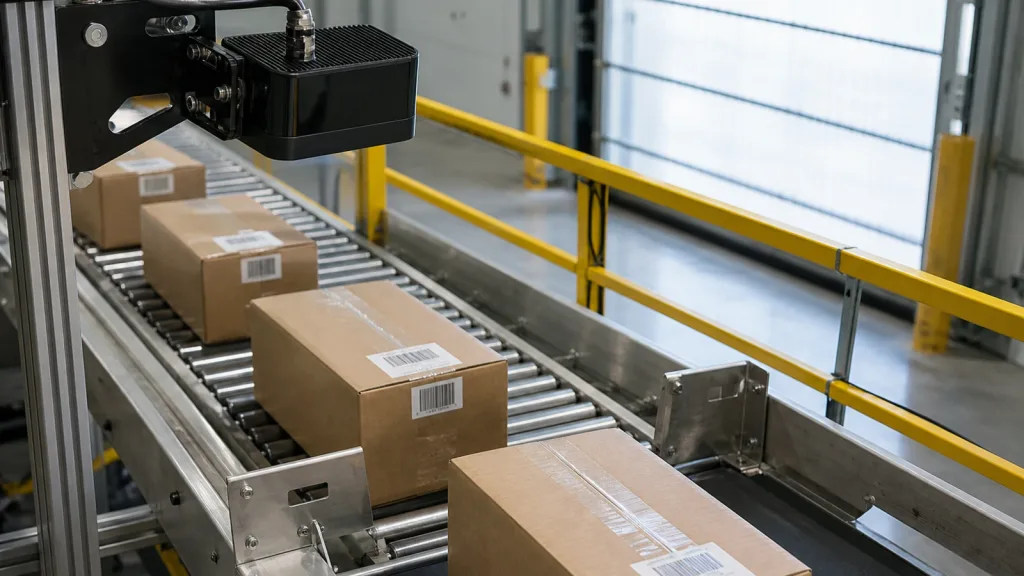
Buy solid state LiDAR by brochure alone and you usually approve the wrong sample. The failure appears later, when a compact module that looked fine on a bench reaches a live workcell with glossy labels, brushed metal, uneven light, and a host pipeline that cannot replay what the sensor actually saw.
This guide is for OEM sourcing leads, robotics integration managers, and technical buyers who need a real RFQ decision for a compact module. The question is not whether a supplier can quote range, weight, and eye safety. The question is whether the sample can keep the target zone readable, the integration path explainable, and the approval evidence useful after the first problem appears.
| Quick answer | Approve a compact solid-state LiDAR sample only after repeated tests prove target-zone fit, reflective-scene stability, Class 1 documentation, and a logging path your team can replay before RFQ sign-off. |
|---|---|
| Best fit | OEM teams evaluating a compact dToF module for robotics, drone integration, or industrial inspection where proof matters more than a generic datasheet comparison. |
| Decision rule | If the team cannot show what the module covered, how it behaved near reflective surfaces, and how the host captured the evidence, the sample is not ready for procurement approval. |
How to buy solid state LiDAR without approving the wrong sample
For a technical buyer, Buy solid state LiDAR should not mean picking the biggest range number in a spreadsheet. It should mean building a sample-approval decision around the application zone that matters: the carton corner, pallet edge, keep-out box, landing corridor, or inspection target the machine actually has to read. NIST's current Measurement Science for Robotics and Autonomous Systems Program is useful here because it treats robotic sensing as a problem of metrics, test methods, and scenarios tied to intended environments rather than as abstract product claims.
That mindset protects buyers from a common mistake. A compact module can be light, low power, and easy to mount, yet still be the wrong purchase if the field of view misses the protected zone or the host path cannot preserve the evidence needed to explain a miss. If your program is specifically UAV focused, Purpleriver already has a narrower guide on how to choose a solid-state LiDAR module for drones. For broader OEM sourcing, the job is to prove the sample inside your own geometry before procurement momentum takes over.
Current research also shows why the scene itself belongs in approval. The 2025 paper Performance Bounds of Ranging Precision in SPAD-Based dToF LiDAR shows that photon flux and pile-up can materially affect ranging precision, which is a reminder that one nominal distance number is not a substitute for scene-specific validation. A 2026 paper from the University of Wisconsin-Madison, Ghosts in the Point Clouds: De-glaring LiDAR in the Transient Domain, highlights how modern solid-state arrays can create severe artifacts around bright or retroreflective surfaces. That matters for real buying decisions because glossy labels, metal edges, reflective wrap, and safety markings are normal in production work, not edge cases.
Safety documentation belongs in the same gate. The FDA's current Laser Products and Instruments guidance explains how laser hazard classes and compliance responsibilities are handled in the U.S. If procurement cannot confirm the right class, labeling, and manufacturer documentation at sample stage, the buying process is already weaker than it should be.
Shortlist decision table
| Evaluation area | What to ask or measure | Approve if | Reject if |
|---|---|---|---|
| Target-zone fit | Does the mounted sample keep the required obstacle face, carton corner, floor box, or landing corridor inside the usable cone? | The protected zone stays readable at the real stand-off distance and mounting angle. | The coverage works only in a simplified setup or misses the decision edge that actually matters. |
| Reflective-scene behavior | How does the sample behave near glossy labels, shrink wrap, brushed metal, or bright light transitions? | Repeated runs remain stable enough for the downstream decision and can be reviewed later. | The sample creates unstable boundaries, phantom depth, or unexplained dropouts when the scene becomes slightly harsher. |
| Laser-safety evidence | Can the supplier provide the class claim and supporting documentation that the buyer must verify? | The safety claim is documented and consistent with the sample being evaluated. | The class is quoted informally or cannot be tied to the actual sample version. |
| Data-path proof | Can the team log output, timing, and scene notes through the chosen interface without changing transports between passes? | A failure can be replayed without rebuilding the entire test cell. | The logs are too weak to tell whether the problem came from optics, transport, parsing, or robot logic. |
| Host and software fit | Does the sample reach the actual OS and host path the team expects to use in development? | The fastest evaluation path also tells the team what must change before deployment. | The demo works only on a one-off setup that the production team will not keep. |
| Approval discipline | Did the team freeze the mount, the scene, and the pass-fail rule before comparing samples? | The comparison is repeatable enough that two engineers would reach the same conclusion. | The sample wins because the setup drifted, not because the module solved the task. |
Exact featured-product facts to confirm
The current Featured WooCommerce product for this workflow is the LiDAR Drone Module - MRP-LD1 Solid-State dToF Sensor. The table below keeps the buying discussion inside verified product truth.
| Parameter | Published value | What the buyer should verify in the sample |
|---|---|---|
| Ranging principle | dTOF | Check time-based depth behavior in the target zone, not just a pass or fail trigger. |
| Scanning principle | SPAD | Stress the sample in scenes where photon load and reflectivity can change the result. |
| Wavelength | 940nm VCSEL | Include the real window materials, labels, and surface finishes from the intended machine. |
| Laser safety | Class 1 (FDA recognized eye-safe) | Confirm the documentation and labeling that procurement will rely on for approval. |
| Range | Indoor 0.5-25m / outdoor 0.2-8m | Translate these numbers into the actual mounting distance and protected zone for your program. |
| Ambient-light resistance | 80Klux | Turn the claim into a measured scene test near the lighting transitions your machine will see. |
| Accuracy | 0.2-1m <= +/-3cm; 1-5m <= +/-5cm; 5-8m <= +/-10cm; 8-15m <= +/-20cm | Set pass-fail tolerances around the real geometry that the machine must protect. |
| Field of view | 60 degrees x 45 degrees | Map whether the required box, lane, or target stays inside the usable cone after mounting. |
| Output | 40 x 30 at 10fps | Verify that granularity and update cadence are enough for the downstream decision path. |
| Interfaces | UART / UVC / UDP | Choose the earliest path that makes proof capture easiest before optimization narrows the transport. |
| Software support | Windows / ARM / Linux / Android | Prototype fast, but prove at least one host path that resembles your real program. |
| Power / weight | 5V, 1.2W, 8g | Treat compactness as integration convenience, not as evidence that the sensing task is solved. |
OEM sample-approval workflow
1. Define one protected decision zone before you compare samples
Pick one decision that the machine must get right: a carton corner entering a merge box, a drone approaching a landing edge, a robot clearing a pallet face, or an inspection head avoiding a fixture. If the team still needs the broader discipline around fixture setup and pass-fail structure, start with Purpleriver's LiDAR sensor validation guide, then narrow the work to the single zone that should govern the buying decision.
2. Convert published range and FoV into mounted geometry
Most buying errors start when teams treat range and FoV as supplier language instead of as mounted geometry. Plot the sensor height, pitch, and target distance. Then ask whether the exact protected edge stays inside the usable view when the machine is where it will really be, not where the demo was easiest to run.
3. Stress the sample with reflective materials and light transitions
Do not keep the test scene cleaner than the production scene. If the program includes glossy labels, shrink wrap, brushed aluminum, floor tape, or daylight leaking through a dock or doorway, bring those elements into the sample run. The 2026 de-glare paper is useful precisely because it reminds buyers that reflective artifacts can be structural, not cosmetic. A sample that passes only in a matte, evenly lit corner has not earned an RFQ.
4. Choose the logging-first interface before you optimize the stack
The earliest approval work should favor explainability over elegance. UVC is often the fastest path for visualization, UART can be convenient for embedded bring-up, and UDP can be powerful when the network and timestamp path are already disciplined. Before you narrow that choice, review Purpleriver's UART, UVC, or UDP guide and decide which path will let the team replay the cleanest evidence.
5. Verify safety and documentation together with sensing behavior
Procurement should not wait until the end to ask about safety or integration documents. Check the class claim, the sample version, the interface notes, and the documentation set while the sample is still being judged. Use the documentation hub and sample datasets as part of the approval pack, not as afterthoughts.
6. Approve only if another engineer can replay the failure later
If a supplier sample is truly ready for RFQ, another engineer should be able to review the logs, scene notes, and capture path and understand what went right or wrong. If that handoff is impossible, the team is still buying with hope rather than with evidence.
Interface, data, and integration questions
The MRP-LD1 brief includes several exact integration facts that buyers can use during sample approval. These belong in the review because an opaque transport path can destroy an otherwise good sensor decision.
| Integration topic | Verified fact | Approval question |
|---|---|---|
| UART bring-up | UART should use 921600 or 460800, 8N1, no parity, and no flow control. | Can the team capture clean logs without transport confusion during the first proof runs? |
| UVC evaluation path | UVC uses YUYV; 40 x 30 is depth, 160 x 120 is point cloud, 120 x 90 is mixed, and 480 x 360 is full data. | Which mode gives the fastest trustworthy view of what the sample is doing in the protected zone? |
| UDP parsing | Each UDP sensor-data frame is 4873 bytes, with 73 bytes of header and 4800 bytes of pixel data. | Can the host parse, timestamp, and archive the frame path well enough for replay after a failure? |
| Time synchronization | UART can output PPS millisecond offset, and UDP mode supports time sync through TCP on port 8081. | Can the review show what the machine decided and what the sensor reported at the same moment? |
| Software support | Documented host support includes Windows, ARM, Linux, and Android. | Is the sample being approved on a host path the actual program can keep after procurement? |
If the sample behaves inconsistently and the logs still do not explain why, revisit Purpleriver's guide to common LiDAR integration issues before blaming the optics alone.
Realistic application case: carton-merge qualification in a packaging workcell
Consider an OEM team evaluating a compact solid-state LiDAR module above a short carton-merge conveyor. Brown cartons with glossy barcode labels and occasional shrink wrap enter from the left, pass under a bracketed sensor, and move toward a protected merge point beside a yellow guardrail. Diffuse daylight leaks through a translucent dock door at the back of the workcell.
The team does not need to prove general warehouse autonomy. It needs to prove one buying decision: whether the module can keep the carton corner and merge boundary readable enough for a diverter or robot handoff routine to react consistently, and whether the evidence survives review after a miss.
- Mount the sample at the real production height and pitch, not the easiest bench angle.
- Run cartons with matte labels first, then repeat with glossy labels and reflective wrap.
- Repeat the same passes with the dock door brighter, dimmer, and half shaded.
- Capture output through one fixed interface path so the comparison stays fair.
- Reject the sample if the carton corner or merge boundary becomes ambiguous when the scene changes only slightly.
This case stays inside the MRP-LD1's documented application scope for robotics and industrial inspection while giving procurement a concrete reason to approve or reject the sample.
Common mistakes
- Buying from headline range numbers without mapping the mounted geometry that actually matters.
- Using a clean static demo instead of the reflective materials and light transitions the machine will really face.
- Switching between UART, UVC, and UDP during comparison runs and then trusting the result anyway.
- Accepting a Class 1 claim without linking it to the sample version and supporting documentation.
- Approving the sample before another engineer can replay the captured failure path.
- Treating compact size and low power as proof that the perception task is already solved.
RFQ and evaluation checklist
| Checklist item | Why it belongs in the RFQ gate |
|---|---|
| Protected-zone definition | Prevents the team from approving a sensor that solves the wrong problem well. |
| Mounted geometry sketch | Turns FoV and range into something procurement and engineering can both review. |
| Reflective-scene test notes | Shows whether the sample was judged under materials that resemble the real machine. |
| Safety-document pack | Makes the class claim usable in a real purchasing process. |
| One fixed logging interface | Keeps the evidence comparable from pass to pass. |
| Repeated-run results | Distinguishes robust behavior from one favorable demo. |
| Replayable failure example | Proves the sample can be debugged after approval pressure begins. |
| Named follow-up owner | Clarifies whether the next step belongs to optics, firmware, host parsing, or machine integration. |
When a compact LiDAR sample is finally ready for procurement
A solid-state module is ready for RFQ only when the sample stays readable in the real scene, the safety claim is documented, and the integration path leaves behind proof that another engineer can trust. Until then, buying pressure should not outrun validation discipline.
Purpleriver's featured MRP-LD1 module is relevant for teams evaluating compact dToF sensing in robotics, drones, and industrial inspection. To discuss fit for your own target zone, use the contact page and include the mounting geometry, target materials, host interface, and lighting transition you need to validate.