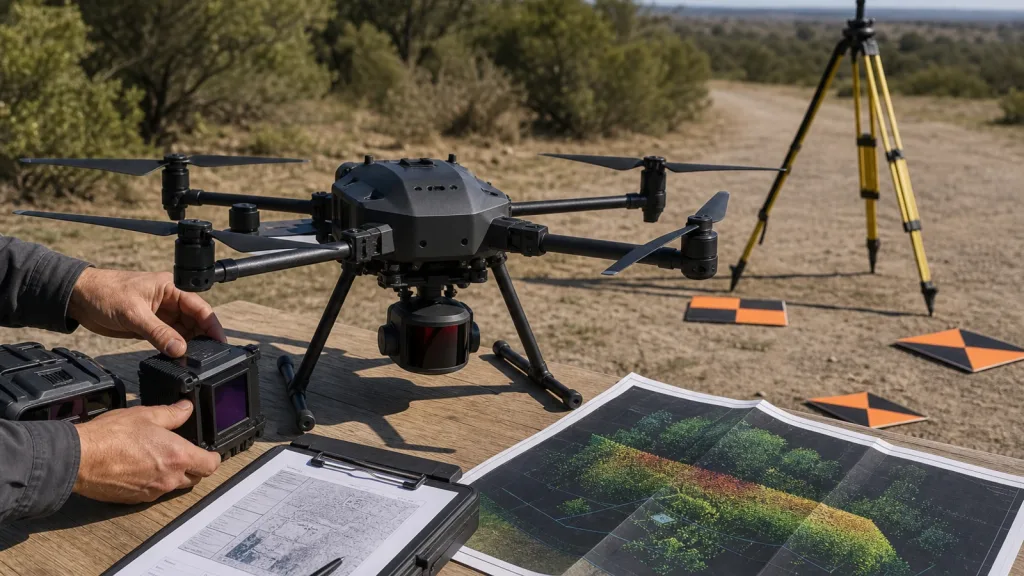
LiDAR for UAV can mean two very different buying paths. One path is a compact onboard sensor for obstacle avoidance, terrain following, or short-range 3D perception. The other is a survey-grade aerial mapping stack that must hold up under checkpoint testing, swath-consistency review, and customer deliverable requirements. Many teams waste time because they compare sensors before they decide which path their project is actually on.
This guide is for survey managers, UAV program leads, and technical buyers who need a practical pre-purchase workflow. It uses real buyer concerns such as “Is drone LiDAR actually worth it for surveying?” and “What kind of accuracy do clients actually need?” as editorial cues only, then grounds the answer in authoritative lidar standards and the exact featured-product facts available on this site.
| Quick answer | Choose LiDAR for UAV only after you define the mission, the required deliverable, the checkpoint and QA burden, and whether you need a compact near-range module or a full survey payload with GNSS/IMU processing and formal mapping reports. |
|---|---|
| Best fit | Teams comparing a lightweight dToF integration path against a survey-grade mapping workflow for corridor checks, terrain-following support, inspection, or early data-collection planning. |
| Decision rule | If the customer expects defensible topographic deliverables, checkpoints, and swath-level QA, buy for the mapping workflow first. If the mission is near-range perception on the aircraft, buy for onboard sensing first. |
Where LiDAR for UAV actually fits
The first mistake buyers make is treating every UAV LiDAR option as if it solves the same problem. A compact solid-state dToF module is usually chosen because weight, power draw, and onboard perception matter. A mapping payload is chosen because the mission lives or dies on trajectory quality, checkpoint design, interswath consistency, and the quality of the final point cloud or DEM deliverable.
That distinction matters because the current USGS Lidar Base Specification and the ASPRS Positional Accuracy Standards frame aerial lidar work around measurable acquisition and reporting requirements, not just sensor marketing language. If your buyer conversation includes checkpoints, control, metadata, swath overlap, or deliverable acceptance, you are already beyond a simple “which module has the best range” comparison.
On the Purpleriver side, the featured MRP-LD1 LiDAR drone module is a compact SPAD dToF sensor positioned for UAV obstacle avoidance, altitude hold, terrain following, robotics, and short-range 3D sensing workflows. It should be evaluated honestly within that envelope, not stretched into promises about survey outcomes the product export does not claim.
Decision table for buyers
| Buyer situation | What usually matters most | Better path |
|---|---|---|
| You need obstacle avoidance, low-altitude support, terrain following, or short-range spatial awareness on the aircraft. | Weight, power, field of view, interface options, companion-computer fit, and how quickly you can test depth output in flight or on a bench. | Compact onboard LiDAR module. |
| You need survey deliverables for a client, defensible accuracy reporting, or a repeatable mapping production workflow. | GNSS/IMU processing, control and checkpoints, swath consistency, point-cloud QA, metadata, and downstream deliverables. | Survey-grade aerial mapping payload and workflow. |
| You are still unclear whether the program is about onboard sensing or formal mapping output. | Mission definition, acceptance criteria, and who will sign off on the data. | Pause the sensor comparison and clarify the job first. |
If your team is still mixing those paths together, review the site's drone LiDAR terms guide before you request quotes. It will shorten the conversation around FOV, frame rate, depth output, and point-cloud expectations.
Exact featured-product parameters
The table below uses only the exact featured-product export fields available for the current Purpleriver module. That means it is safe to use for shortlist decisions, but it should not be expanded into claims that are not explicitly present in the export.
| Parameter | MRP-LD1 exported fact | Why a UAV buyer should care |
|---|---|---|
| Technology | SPAD dToF solid-state LiDAR with 940nm VCSEL | Relevant for buyers comparing compact direct time-of-flight sensing against heavier scanning payloads. |
| Range | Indoor: 0.5-25m; outdoor: 0.2-8m | Useful for near-range perception and validation tasks, but not a substitute for a survey workflow definition. |
| Resolution | 40×30 depth output | Helps buyers judge whether the module supports the spatial detail needed for obstacle, edge, or zone decisions. |
| Frame rate | 10fps | Important when the aircraft or target scene is moving and you need timely depth updates. |
| Field of view | 60°(H) × 45°(V) | Shapes mounting position, blind-zone behavior, and the amount of scene covered per frame. |
| Interfaces | UART, UVC, UDP | Directly affects integration with flight controllers, companion computers, and replay workflows. |
| Power and weight | 1.2W and 8g | Useful when payload budget and flight endurance are tight. |
| Software support | Windows, ARM, Linux, Android | Helps teams plan bench testing and embedded integration without assuming a custom toolchain from day one. |
A pre-purchase workflow for mapping and perception teams
1. Start with the deliverable, not the sensor
If the buyer cannot state whether success means “avoid that obstacle,” “hold altitude over uneven ground,” or “deliver a point cloud and DEM the client can defend,” the comparison is premature. The deliverable determines whether your real bottleneck is onboard sensing or geospatial production.
2. Write down the acceptance test
For compact onboard sensing, the test may be a repeatable clearance or terrain-following task. For aerial mapping, the test expands into checkpoints, swath overlap behavior, coordinate reference system handling, and the reporting chain expected by the customer. The USGS data-processing requirements explicitly call for checkpoint independence, interswath review, and documented validation before derivative products are accepted.
3. Separate payload fit from mapping fit
A lightweight module may be perfect for early UAV sensing work because it preserves payload margin and integrates quickly over UART, UVC, or UDP. That does not automatically make it the right choice for a project whose buyer expects mapping-grade acquisition logistics, field control, and survey reporting. If the aircraft mission is near-range perception, compactness wins. If the program is about final mapping deliverables, control and QA discipline win.
4. Budget for control, checkpoints, and review time
The most overlooked cost in LiDAR for UAV procurement is not always the payload. It is the field and office workflow needed to prove accuracy. The USGS deliverables guidance requires survey reporting, control-point usage disclosure, checkpoint documentation, and lidar mapping reports. The USGS data-processing requirements also incorporate current ASPRS accuracy methods, including survey error in vertical-accuracy calculations, checkpoint independence, and interswath review.
5. Decide how the data will be consumed
If your team mostly needs rapid depth cues on the aircraft or quick bench replay, review the site's guide to UART, UVC, and UDP interface choices. If your team needs downstream analysis or customer-facing datasets, inspect available sample datasets and compare them against the point-cloud checks in this site’s dataset evaluation workflow.
Interface, data, and integration planning
For a compact module such as MRP-LD1, the integration question is usually: how fast can the team mount the sensor, capture depth output, and prove that the output is usable in the target UAV stack? The module’s exported interfaces create different evaluation paths:
| Interface | Typical evaluation use | Buyer question |
|---|---|---|
| UART | Embedded integration and low-level serial parsing with the flight stack or companion computer. | Who owns protocol parsing, timing, and logging when something goes wrong in flight? |
| UVC | Fast bench visualization of depth or point-cloud style outputs on a host system. | Can the team validate scene coverage and blind zones before custom middleware is written? |
| UDP | Higher-throughput networking and replay-oriented workflows. | Where will packet logging, timestamp handling, and network reliability be verified? |
A practical pattern is to use UVC or UDP for fast visual proof, then move to the interface that matches the aircraft architecture. For teams building a documentation-backed evaluation routine, start with the site’s documentation resources and then compare replay behavior against a known point-cloud workflow.
Realistic application case
A corridor-survey team deciding whether compact LiDAR is enough
A regional engineering team is preparing a UAV proposal for utility-corridor work. The procurement lead hears “LiDAR for UAV” and assumes a lightweight module will cover both near-range obstacle support and final survey output. The processing lead pushes back: the client will ask about checkpoints, control, deliverables, and QA documentation, not just whether the aircraft can detect nearby terrain.
The team runs a two-track evaluation. Track one asks whether a compact dToF module can improve low-altitude awareness during field validation flights. Track two asks what a mapping-grade payload and workflow would require to satisfy customer expectations. The result is not a fight over one sensor. It is a clean procurement split: a compact module may support operational awareness, but the survey deliverable still requires a dedicated mapping workflow.
That is the right outcome. The buyer did not confuse an onboard sensing tool with a formal aerial mapping program, and the quote can now describe both pieces honestly.
Common mistakes
- Comparing range numbers before you define the deliverable and the customer’s acceptance test.
- Assuming a lightweight onboard module automatically replaces a survey payload and GNSS/IMU workflow.
- Ignoring checkpoint design, swath consistency, or mapping reports until after the purchase order is approved.
- Choosing an interface without deciding how the team will log, replay, and debug data.
- Treating Reddit anecdotes as facts instead of as clues about what buyers are confused about.
- Requesting a quote without asking for sample data, documentation, and a realistic validation path.
RFQ and evaluation checklist
| Question | Why it matters |
|---|---|
| Is this purchase for onboard perception, mapping deliverables, or both? | This decides whether compactness or survey workflow should dominate the shortlist. |
| What point-cloud, DEM, or report must the customer accept? | Deliverables determine the QA burden and whether standards-based validation applies. |
| What payload, power, and flight-time margin can the aircraft spare? | A technically good sensor still fails if the airframe cannot support it. |
| Which interface will be used first for proof, and which one will be used in deployment? | This reduces integration churn and makes test evidence easier to collect. |
| Who owns checkpoint planning, QA review, and final reporting if the work is survey-facing? | The real bottleneck is often workflow capacity, not sensor capability. |
| What sample data, documentation, and replay assets can the vendor provide now? | Early validation shortens the decision cycle and exposes hidden integration risk. |
Need a clearer UAV LiDAR shortlist?
If your team is comparing compact onboard sensing against a survey-grade mapping workflow, start with the operational goal, then match the sensor and validation plan to that goal. For a lightweight SPAD dToF option, review the Purpleriver featured module details, available documentation, and sample-data resources before you request a quote or start custom integration.
Review the MRP-LD1 product page or use the contact page to outline your UAV mission, data path, and evaluation criteria.