
DOCX
Request access
MRP-LD1 User Manual EN
English product and operating reference for technical evaluation and setup planning.
Drone LiDAR sitemap pages are being expanded with product-led technical content.
Explore the moduleMRP-LD1 Technical Resources
Access MRP-LD1 manuals, SDK information, point-cloud sample requests and dToF LiDAR FAQs for UAV and embedded integration evaluation.

Choose a resource
Start with product documentation, request representative data for validation or review common technical and commercial questions.

Review the MRP-LD1 user manual, public product specifications and SDK access path before integration.
Manual · SDK · Specs ›
Request representative depth or point-cloud material matched to the intended scene, range and host workflow.
Scene-matched request ›
Check product limits, evaluation planning, technical support and commercial questions before contacting the team.
Product · Integration · Buying ›Available technical materials
The public specification can be reviewed immediately. The user manual and SDK package use the shared inquiry flow, while sample data is matched to the intended scene and validation goal.
English product and operating reference for technical evaluation and setup planning.
Development package for host-side evaluation after the application and platform are identified.
Review documented range, field of view, depth output, frame rate, weight and power.
Describe the application scene and validation goal so representative sample material can be matched.
Evaluation baseline
Use these public values for initial screening, then confirm the host interface, protocol and SDK path before hardware integration.
Evaluation path
Compare range, field of view, output, weight and power with the platform requirements.
Review specifications › 02Identify the host, software environment and interface requirements before requesting development files.
Open documentation › 03Request representative depth or point-cloud material for the intended scene and evaluation goal.
Request sample data › 04Share application, quantity, project stage and timing for a sample or quotation discussion.
Send requirements ›Technical reading
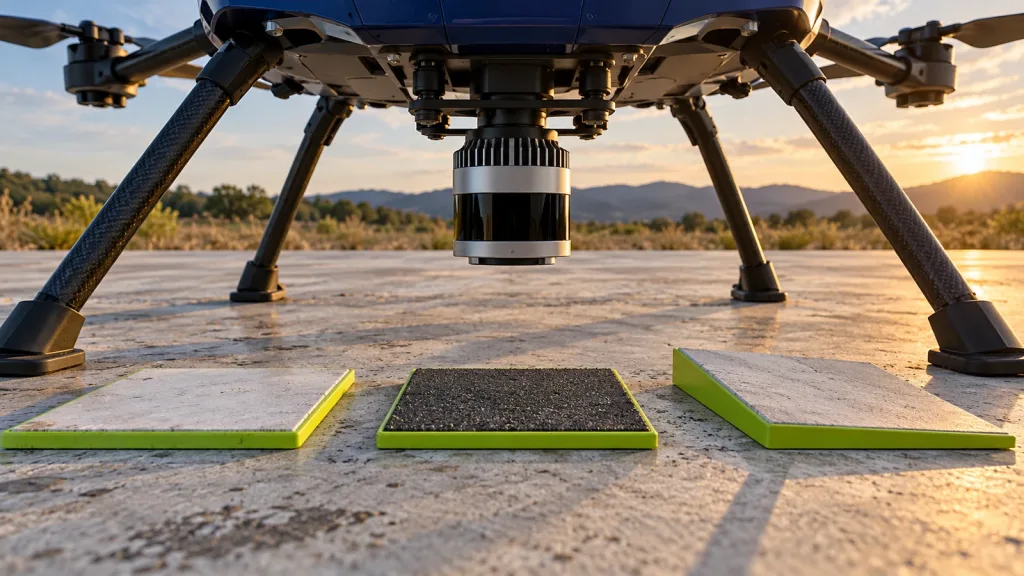 Drone Obstacle Avoidance
A practical downward sensing validation guide for UAV teams: prove the installed view, representative ground evidence, host data contract, and tested handoff before treating a compact depth module as a low-altitude input.
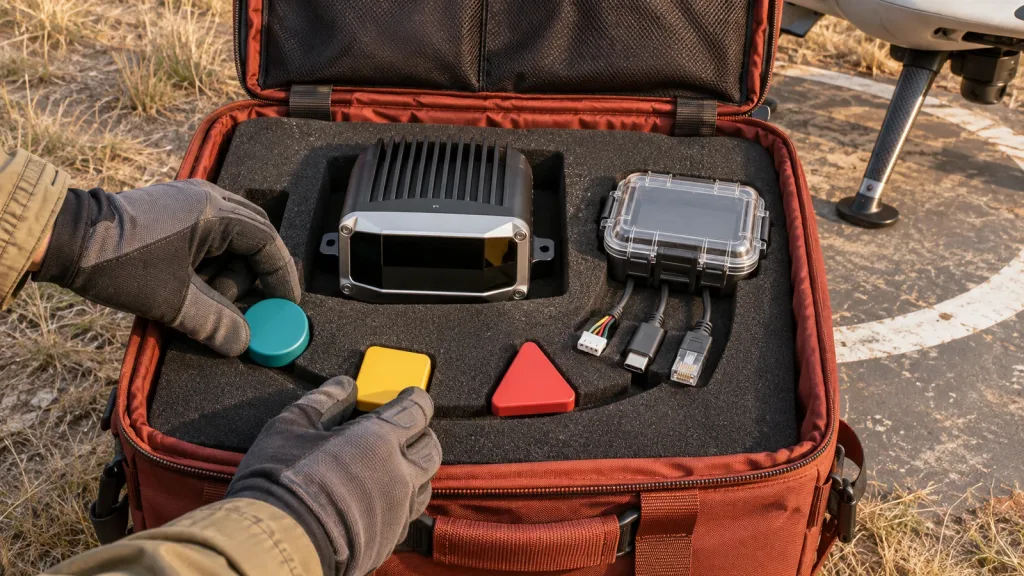 Integration & SDK
Build a repeatable evidence pack for LiDAR SDK Windows Linux Android ARM evaluation before an embedded or field-pilot handoff.
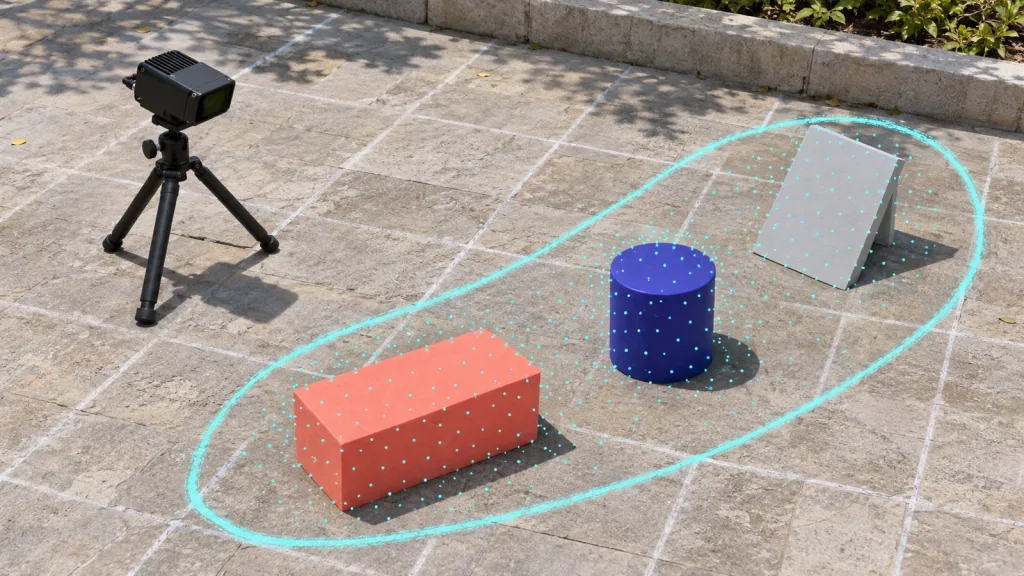 Data & Point Cloud
A practical, repeatable workflow for turning compact dToF depth output into an inspectable point cloud before labeling, model work, or an application pilot.
Share the application, target distance, host environment and project stage so the right resources can be matched.
Drone LiDAR Quote
Share quantity, platform and integration needs. Justin Lu can follow up with quote, sample or technical support details.
Resource unlocked
Your inquiry has been submitted. You can download the requested resource now.
Download resource